Author: DADI Technical Team
Technical basis: DADI electronic theodolite design and manufacturing experience, with selected angle-measurement principles provided and confirmed by Mr. Ronghua Zhou
Updated: September 2026
Quick Answer
An electronic theodolite measures an angle by converting the mechanical rotation of its horizontal or vertical measurement axis into digital angular-position information. Each measurement axis has its own encoder disk and photoelectric reading system. The system first determines a coarse angular position and then identifies a finer position within that angular interval. These two parts are combined into a unique angular position. The final displayed angle also depends on encoder-disk accuracy, axis-system accuracy and software correction. In an absolute encoder system, the instrument can determine its current angular position directly without first searching for a reference position.
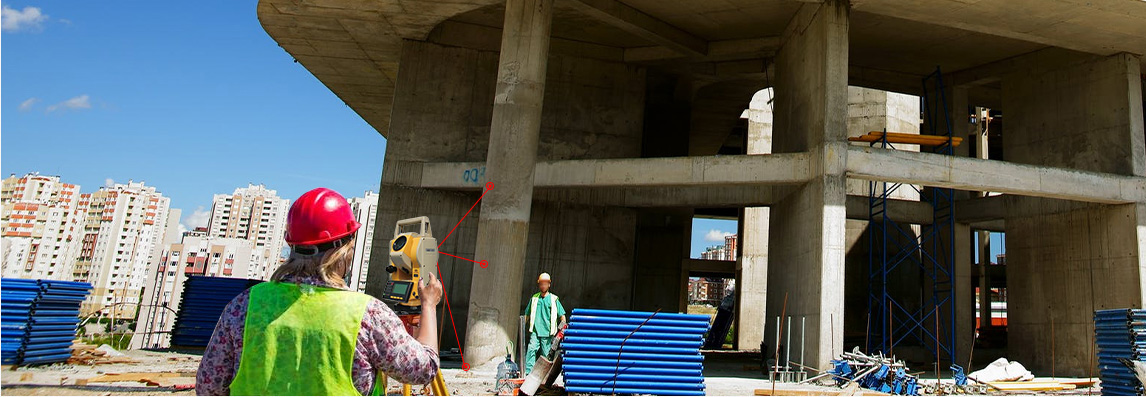
An electronic theodolite is fundamentally an angle-measuring instrument. Its two principal measurements are the horizontal angle and the vertical angle. When the telescope is turned horizontally or tilted vertically, the instrument determines the corresponding angular position and displays it digitally.
This distinction is important because an electronic theodolite should not be confused with a total station. A total station also performs electronic angular measurement, but it additionally incorporates electronic distance measurement, commonly referred to as EDM, and can use measured angle and distance information for further coordinate calculations.
The measurement process begins optically. The operator looks through the telescope and uses the reticle or crosshair to sight the required target. The direction represented by the telescope is commonly described by its line of sight or collimation axis.
When the telescope or instrument body is rotated, the corresponding mechanical measurement axis also rotates. The electronic angle-reading system must then determine the angular position associated with that rotation.
The instrument is therefore not simply reading an isolated electronic sensor. It is determining the direction of the telescope through a complete system that includes the optical sighting direction, mechanical axes, encoder components and electronic processing.
Engineering point: The final angular measurement depends on more than the encoder alone. The relationship between the line of sight, mechanical axis system, encoder reading and subsequent correction also matters.
In DADI electronic theodolites, horizontal-angle measurement and vertical-angle measurement use independent encoder-disk reading systems.
| Measurement | Angle-Reading System | Function |
|---|---|---|
| Horizontal Angle | Independent encoder disk and reading system | Determines angular position around the horizontal measurement system |
| Vertical Angle | Independent encoder disk and reading system | Determines the telescope's vertical angular position |
Each encoder disk is installed perpendicular to its corresponding rotational axis. In other words, the disk plane and the corresponding axis form a 90-degree relationship. As the measurement axis rotates, the angular position represented by the disk changes accordingly.
The exact mechanical mounting dimensions and internal assembly parameters are instrument-design details and are not required in order to understand the basic measurement principle.
DADI also carries outhorizontal and vertical axis inspectionduring the manufacturing process. This provides practical manufacturing evidence for the mechanical axis system discussed in this article.
The encoder disk is one of the core components that allows an electronic theodolite to convert mechanical rotation into readable angular-position information.
Conceptually, the disk contains a large number of precision marks, lines or encoded optical structures. These features carry angular-position information. As the corresponding measurement axis rotates, the position of the encoder disk changes relative to the optical reading system.
The exact number of marks and the specific encoding arrangement depend on the encoder design. DADI's actual number of encoder divisions and its detailed encoding method are not disclosed here because they belong to the implementation of the angle-reading system.
As part of its manufacturing and inspection process, DADI performsabsolute encoder disk inspectionbefore the encoder becomes part of the complete electronic angle-measurement system.
| Component | Function |
|---|---|
| Light Source | Provides the optical illumination required for reading the encoder disk. |
| Encoder Disk | Changes angular position with the corresponding measurement axis and carries angular-position information through precision marks or encoded optical structures. |
| Photodetector / Photoelectric Receiver | Detects optical changes associated with the encoder disk and converts them into electrical signals that can be processed electronically. |
| Electronic Processing | Uses the detected position information to determine the corresponding angular position. |
At this level, it is sufficient to understand the functional chain. The specific optical signal form, circuit parameters, encoding rules and signal-processing algorithms belong to the detailed implementation of the encoder system.
A useful way to understand the DADI angle-reading principle is to separate the measurement conceptually into two parts: a coarse angular position and a fine angular position.
The first task is to determine the angular interval in which the measurement axis is currently positioned. This can be described as the coarse angular position.
In practical engineering discussion, this coarse component can be understood as the "large number" of the angle reading. It establishes the broader angular region before the finer position inside that region is determined.
The reading system then determines a more precise position within the identified angular interval. This is the fine angular position or fine reading.
This fine component can be understood as the "remainder" of the complete angular reading. It supplies the additional subdivision needed to determine the precise location within the coarse angular interval.
This coarse-plus-fine description is the key conceptual step between mechanical rotation and a digital angular value. The coarse reading establishes the angular interval, while the fine reading determines the more precise position within that interval.
Technical boundary: This article does not describe how the coarse position is looked up, how the coarse code is determined, the internal data structure, the actual number of encoder marks, the fine-subdivision algorithm, whether a particular phase method is used, whether sine/cosine interpolation is used, the interpolation method, signal waveforms or proprietary software algorithms. These belong to DADI's specific technical implementation.
An absolute encoder allows the angle-reading system to determine the current absolute angular position directly. The instrument does not first have to search for a reference position before it can identify its present angular position.
For an electronic theodolite, this means that the encoder system provides position information that can be associated with a unique angular position rather than simply recording how far the instrument has moved from an earlier position.
The specific encoding arrangement used to produce this absolute-position information is an implementation detail and is separate from the functional definition of an absolute encoder.
| Characteristic | Absolute Encoder | Incremental Encoder |
|---|---|---|
| Position Information | Provides information corresponding to the current absolute position. | Primarily measures changes in position relative to a reference. |
| Reference Requirement | The current position can be identified without first searching for a reference position. | A reference or established starting position is generally required to relate incremental movement to an absolute position. |
| Conceptual Difference | Identifies where the axis is. | Identifies how far the axis has moved relative to a reference. |
DADI's DE2A electronic theodolite uses an absolute encoder system. The comparison above concerns the functional difference between absolute and incremental position measurement and does not disclose the specific encoding method used inside the DADI system.
The ability of an encoder to read angular position should not be treated as identical to the final angular accuracy of the complete theodolite.
Based on DADI's electronic theodolite design and manufacturing experience, three principal factors must be considered together:
The accuracy and quality of the encoder disk influence how reliably angular position can be represented and read.
The mechanical axis system influences how accurately the physical direction of the instrument corresponds to the angular position being measured.
Software correction forms part of the complete measurement system and contributes to the final relationship between the measured position and the displayed angular value.
This is why encoder resolution, encoder reading capability or the smallest internal reading step should not automatically be interpreted as the accuracy of the complete instrument. Final angular accuracy is a system-level result.
The importance of the mechanical part of this chain can also be seen in DADI'shorizontal and vertical axis inspection,which provides manufacturing evidence related to the accuracy of the instrument axis system.
Angular accuracy in surveying instruments is commonly expressed in arcseconds. One arcsecond is one three-thousand-six-hundredth of one degree:
TheDADI DE2A 2″ Electronic Theodoliteis specified with 2″ angular accuracy.
This 2″ specification describes the angular measurement performance of the complete instrument. It should not be interpreted to mean that one encoder-disk parameter alone produces the complete 2″ performance.
According to DADI's engineering experience, the complete angular accuracy is associated with encoder-disk accuracy, axis-system accuracy and software correction working together.
Once the electronic reading system has established an angular position, the instrument still has to convert that reading into the final measurement value shown to the operator. Software correction forms part of this complete measurement process.
According to the DADI engineering information used for this article, compensation is principally associated with the fine part of the angular reading and with correction at the arc-second level. It is therefore especially relevant to the fine portion of the measurement rather than simply to identification of the broader angular interval.
The specific correction model, compensation parameters, mathematical algorithms and software implementation are part of the detailed instrument design and are outside the scope of this article.
In surveying practice, angular observations may be made in two telescope orientations commonly called Face I and Face II, also known as direct and reverse observations.
One important purpose of observing in both faces is to reduce or cancel the influence of collimation-axis error on the angular observation.
This also illustrates why electronic angle measurement is not solely an encoder problem. The telescope sighting direction and the mechanical geometry of the instrument remain relevant to the reliability of the final angular observation.
TheDADI DE2A electronic theodoliteprovides a practical example of how these measurement principles are implemented in a current instrument. It uses an absolute encoder angle-reading system and is specified for 2″ angular accuracy.
| DE2A Parameter | Specification |
|---|---|
| Angular Accuracy | 2″ |
| Angle Reading System | Absolute encoder |
| Telescope Magnification | 30× |
| Display | Dual LCD |
| Compensation | Single-axis |
The DE2A example should be understood at system level. Its 2″ angular accuracy is the performance of the complete angle-measurement system rather than a specification that can be attributed only to the encoder disk.
DADI'selectronic theodolite manufacturingexperience treats angular measurement as a complete system rather than as an isolated encoder specification. Encoder-disk accuracy, mechanical axis accuracy and software correction all contribute to the final angular measurement.
During manufacturing, the encoder disk and the horizontal and vertical axis components therefore represent separate but related parts of the angle-measurement chain. DADI'sabsolute encoder disk inspectionandhorizontal and vertical axis inspectionprovide manufacturing evidence related to these two parts of the measurement system.
The instrument also depends on its optical system for target sighting. DADI'soptical component preparationshows another stage of the manufacturing process associated with the complete electronic theodolite.
The purpose of this article is to explain what happens between mechanical rotation and a displayed digital angle. Detailed encoder coding rules, subdivision algorithms, signal waveforms, compensation parameters and proprietary software methods are intentionally outside this explanation.
1. The operator sights the target through the telescope.
2. The telescope or instrument rotates around the corresponding measurement axis.
3. The encoder disk changes angular position with that axis.
4. The photoelectric reading system detects the encoder-disk position.
5. The system determines the coarse angular position.
6. Fine subdivision determines the more precise position inside that angular interval.
7. Coarse and fine information are combined into a unique angular position.
8. Software correction and relevant compensation are applied.
9. The final horizontal or vertical angle is displayed digitally.
An electronic theodolite primarily measures horizontal and vertical angles. It determines the direction of the telescope relative to the instrument's angular measurement system and displays the result digitally.
The rotation of the relevant measurement axis changes the position of an encoder disk. A photoelectric reading system detects the disk position, determines coarse and fine angular information, combines them into a unique angular position and then applies the required correction before displaying the angle.
An encoder disk is a precision component that carries angular-position information through optical marks or encoded structures. Its changing position is read electronically as the corresponding instrument axis rotates.
An absolute encoder provides information that allows the system to determine the current absolute angular position directly, without first searching for a reference position.
An absolute encoder identifies the current position itself, while an incremental encoder principally records changes in position relative to an established reference or starting point.
Two arcseconds equals 2/3600 of one degree, or approximately 0.000556°. In a 2″ electronic theodolite, this is a system-level angular accuracy specification rather than simply the resolution of one encoder component.
Not by itself. In DADI's electronic theodolite design experience, final angular accuracy is associated with encoder-disk accuracy, axis-system accuracy and software correction. Encoder reading capability is therefore only one part of the complete measurement system.
Software correction forms part of converting the measured encoder position into the final instrument reading. In the DADI engineering context described here, compensation is particularly associated with fine-angle information and arc-second-level correction.
One important purpose of using Face I and Face II observations is to reduce or cancel the influence of collimation-axis error and improve the reliability of angular observation.
A standard electronic theodolite is primarily an angle-measuring instrument. A total station extends electronic angular measurement by adding EDM distance measurement and further coordinate-related functions.
Learn about DADI's electronic theodolite manufacturing, development, assembly, inspection and testing capabilities.
See a current electronic theodolite example using an absolute encoder system with 2″ angular accuracy.
See factory inspection evidence for the encoder disk, one of the core components in the electronic angle-measurement system.
See manufacturing and inspection evidence related to the horizontal and vertical axis system that contributes to complete angular measurement accuracy.
See DADI factory information on optical component preparation before electronic theodolite assembly.



Contact our customer support
team 7×24 hours
WhatsApp:+86-18961173276